Featured Project
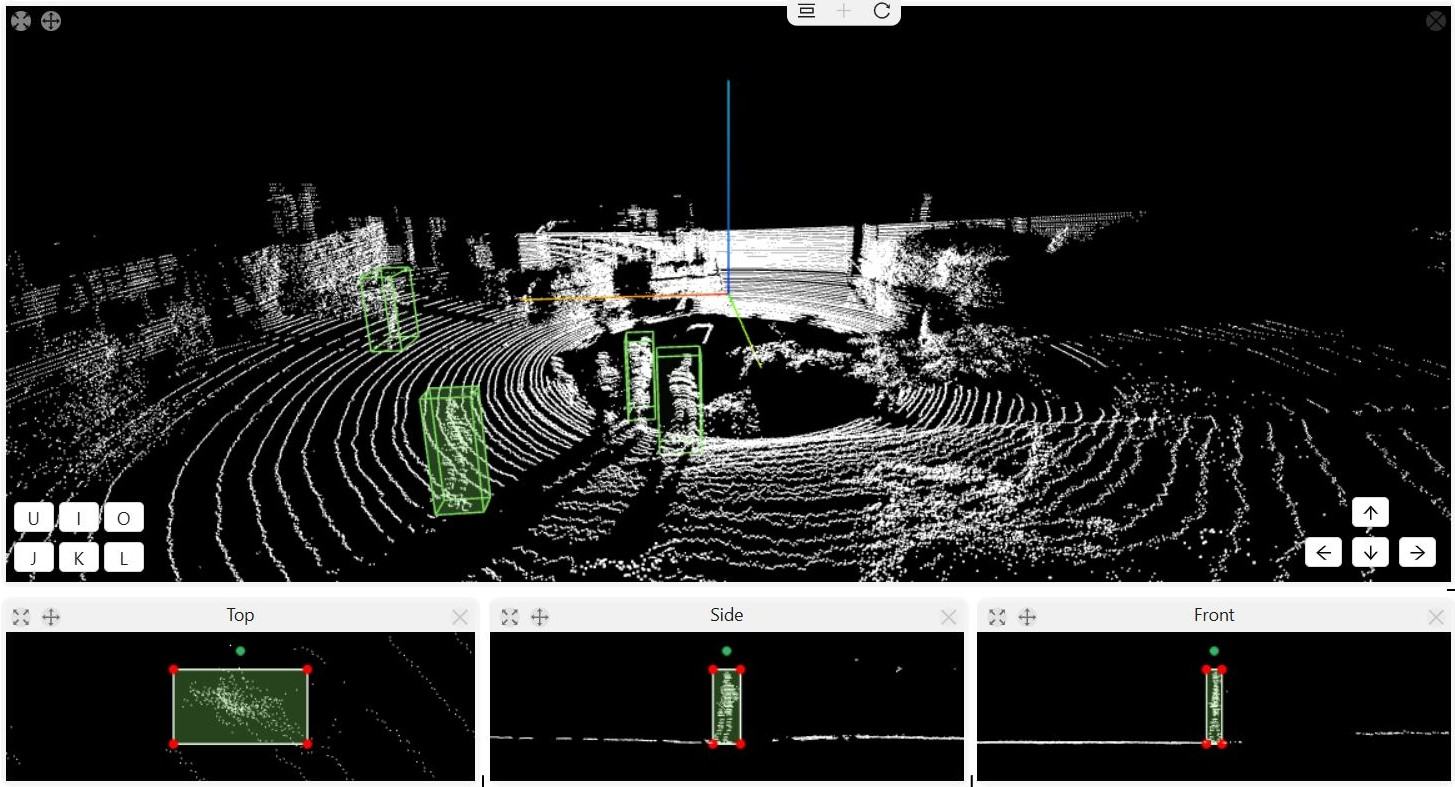
Global 3D viewport showcasing multi-class object detection and cuboid annotation on high-density point cloud frames.
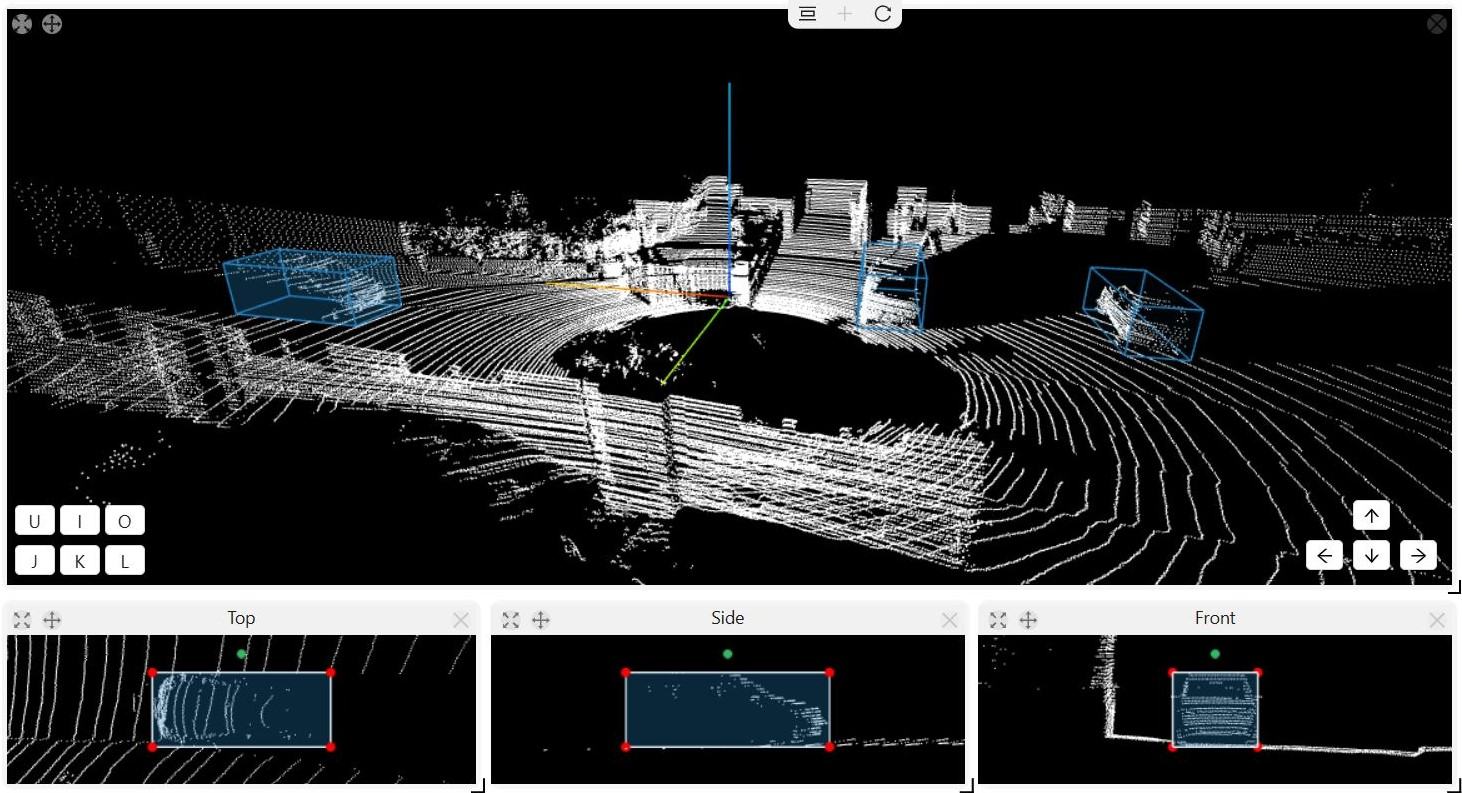
Orthographic multi-view alignment ensuring X, Y, Z dimensional accuracy and tight bounding box margins to eliminate background noise.
Autonomous Vehicles
High-Precision 3D LiDAR Point Cloud Annotation for Autonomous Driving Systems
Annotating .pcd point cloud data with zero margin for error — accurate 3D object detection across sparse, complex three-dimensional space for autonomous vehicle perception stacks.
The Challenge
Annotating 3D point cloud data (via .pcd files) presents unique spatial challenges compared to standard 2D images. Autonomous vehicles require object detection with zero margin for error to navigate safely. The primary challenge was to accurately identify, classify, and isolate overlapping objects in a sparse, complex three-dimensional space (X, Y, Z coordinates), ensuring perfectly tight boundaries around target objects without including environmental noise or stray points.
Our Solution
Utilizing advanced labeling infrastructure, our annotation team executed a meticulous multi-view 3D bounding box strategy. By leveraging synchronous orthographic projections (Top, Side, and Front views), we isolated vehicles, pedestrians, and cyclists. Every single 3D cuboid was manually cross-checked across all views to align perfectly with the object's real-world volume. Strict Quality Assurance (QA) workflows were enforced to verify the orientation vector (Heading/Yaw) of every moving object.
The Deliverables
Fully annotated 3D frames — high-density spatial datasets with precise object tracking · Multi-class cuboids accurately separating vehicles, infrastructure, and vulnerable road users (pedestrians) · Production-ready formats exported as structured JSON, fully compatible with KITTI and custom machine learning pipelines.